Whisker-guided drone navigates by touch in low-visibility conditions
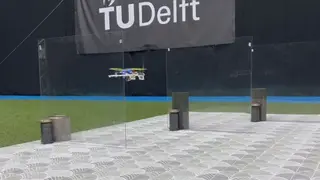
Researchers at Delft University of Technology have created a tactile navigation system for small drones using whisker-like sensors that detect surfaces through pressure changes. The setup, which weighs under 100 grams and runs on just 34KB of software, allows drones to avoid obstacles and map surroundings in dark or dusty environments where cameras and GPS are unreliable. The design mimics the vibrissae of rodents, which use whiskers to move through tight, dark spaces.
The tactile system employs two whiskers mounted at the drone's front, angled upward, with each connected to three miniature pressure sensors at its base. When a whisker brushes against a surface, pressure variations across those sensors let the onboard processor calculate relative depth and position, enabling obstacle avoidance, surface tracking, and area mapping. The researchers also developed a real-time processing pipeline that filters out airflow turbulence from genuine surface contact, achieving millimetric precision despite the minimal hardware footprint.
This design directly mimics rodent vibrissae, which allow small mammals to move confidently through tight, dark spaces. The project was led by Dr. Salua Hamaza and researcher Chaoxiang Ye, who emphasized that the entire perception system operates within a 34-kilobyte memory budget. The intended application is search-and-rescue, where tiny drones could explore collapsed structures in conditions where visual sensors fail, potentially complementing other experimental rescue technologies.
This technology could meaningfully expand drone utility in emergency response, where darkness, dust, and smoke frequently disable conventional navigation. Rescue teams may deploy these lightweight drones to probe unstable rubble or hazardous interiors without risking human lives, and the low computational demands could make the system adaptable to other small autonomous platforms. However, tactile-only navigation remains limited to close-range operations, so its practical impact will likely depend on pairing whisker sensing with other methods rather than replacing them entirely.