Open-source humanoid robot platform unveiled with advanced capabilities
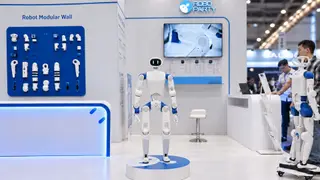
A Pittsburgh-based robotics company has introduced RP1, described as the first fully open-source bipedal humanoid robot with high-performance specifications. The robot represents a significant development in accessible robotics technology by utilizing an open-source architecture that allows for broader innovation and customization. This release signals growing momentum in making advanced robotic systems available to developers and researchers outside proprietary frameworks.
The introduction of RP1 marks a notable shift in the robotics sector toward transparency and collaborative development. By adopting an open-source model, the platform removes traditional barriers that have confined advanced humanoid robotics to well-funded institutions and corporations. This approach enables a distributed network of engineers and researchers to contribute improvements, adapt designs for specialized applications, and accelerate innovation cycles.
The bipedal design with high-performance capabilities addresses longstanding technical challenges in humanoid robotics. Making such systems openly accessible could democratize access to sophisticated robotic platforms, allowing academic laboratories and smaller organizations to participate in development without licensing restrictions or proprietary dependencies.
RP1's open-source framework may reshape how robotic technology diffuses through research communities and industry sectors. Universities, startups, and independent developers could gain practical tools for advancing human-robot interaction, autonomous systems, and manufacturing applications. The broader accessibility might accelerate problem-solving across multiple domains, though realizing these benefits would depend on adoption rates and the quality of community contributions to the platform's ecosystem.