Light-controlled muscle cells propel a tiny swimming robot
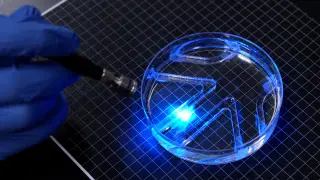
MIT engineers created a thin, gel-based swimmer whose fins are coated with light-sensitive muscle cells. Flashing light on either fin makes it flap, allowing researchers to steer the device through an underwater maze. The robot moved about four body lengths per minute and represents a step toward small biohybrid machines for delicate environments.
The MIT device has a gel body about the size of a stick of gum, shaped into two fins. Each fin carries an extremely thin layer of muscle cells engineered to contract under light. By selecting which fin is illuminated and varying flash frequency, researchers can make it flap, turn, and cross a simple maze. Its top speed was roughly four body lengths per minute—slower than an elite swimmer but similar to a leisurely cow shark.
The researchers describe it as the first ultrathin, flat biohybrid swimmer propelled by lab-grown muscle. Earlier biohybrid robots tended to use chunky three-dimensional skeletal-muscle constructs needing millions of cells; slimmer designs might be cheaper and more efficient.
This work may influence researchers developing small robots for fragile or unpredictable settings, where soft, self-healing materials could reduce disturbance. It could also affect industries that need compact inspection or exploration tools, though such applications remain speculative. Because the device relies on living cells, questions about reliability, maintenance, and care may shape public acceptance and adoption.